Project / Case study
Robotic Arm with Computer Vision
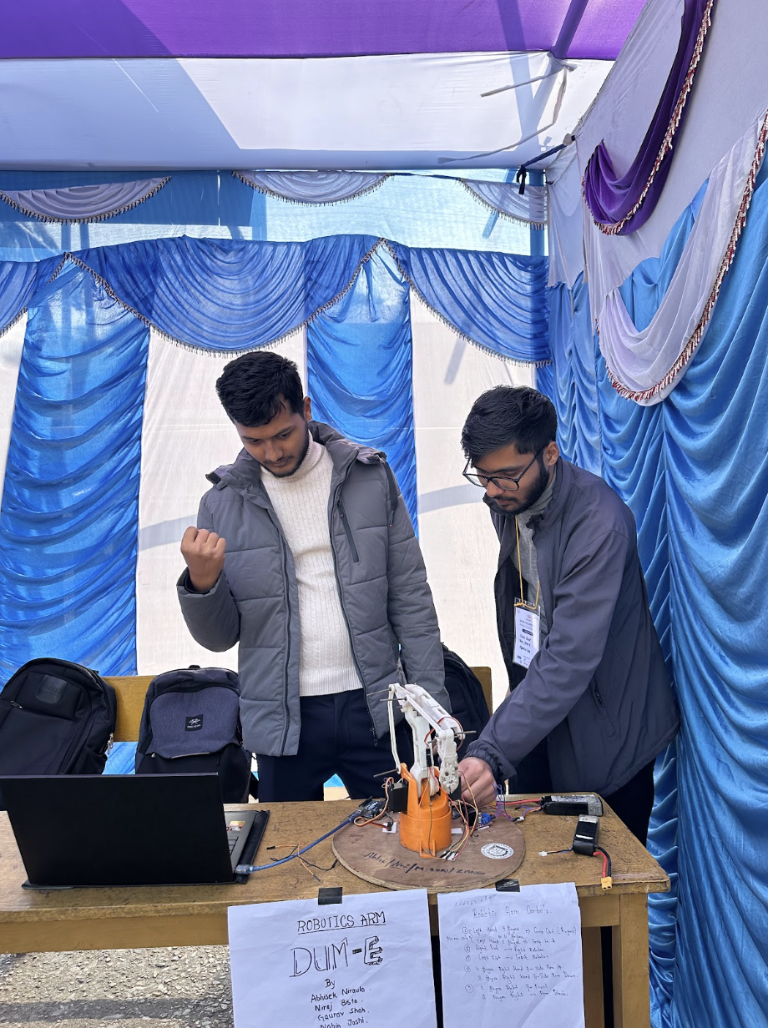
This project uses a webcam and hand tracking to control a robotic arm. MediaPipe detects hand landmarks, Python interprets gestures, and commands travel over serial to an Arduino-driven servo controller.
01 / Research question
What it asks
How can natural hand gestures become reliable controls for a physical robotic arm?
02 / Experimental design
Scope
A webcam captures a single hand, MediaPipe extracts its landmarks, and the Python application identifies finger counts, fists, thumb-to-index distance, and left- or right-hand context. The resulting command is sent to an Arduino over USB serial.
03 / Evaluation
How it measures
The Arduino sketch updates the arm servos through an Adafruit PCA9685 PWM Servo Driver. Gesture mappings provide separate movement commands for left and right hands, including stop, directional motion, and gripper-related actions.